 Hardwareby LUMALIEN · GitHub · open hardware
Hardware · build
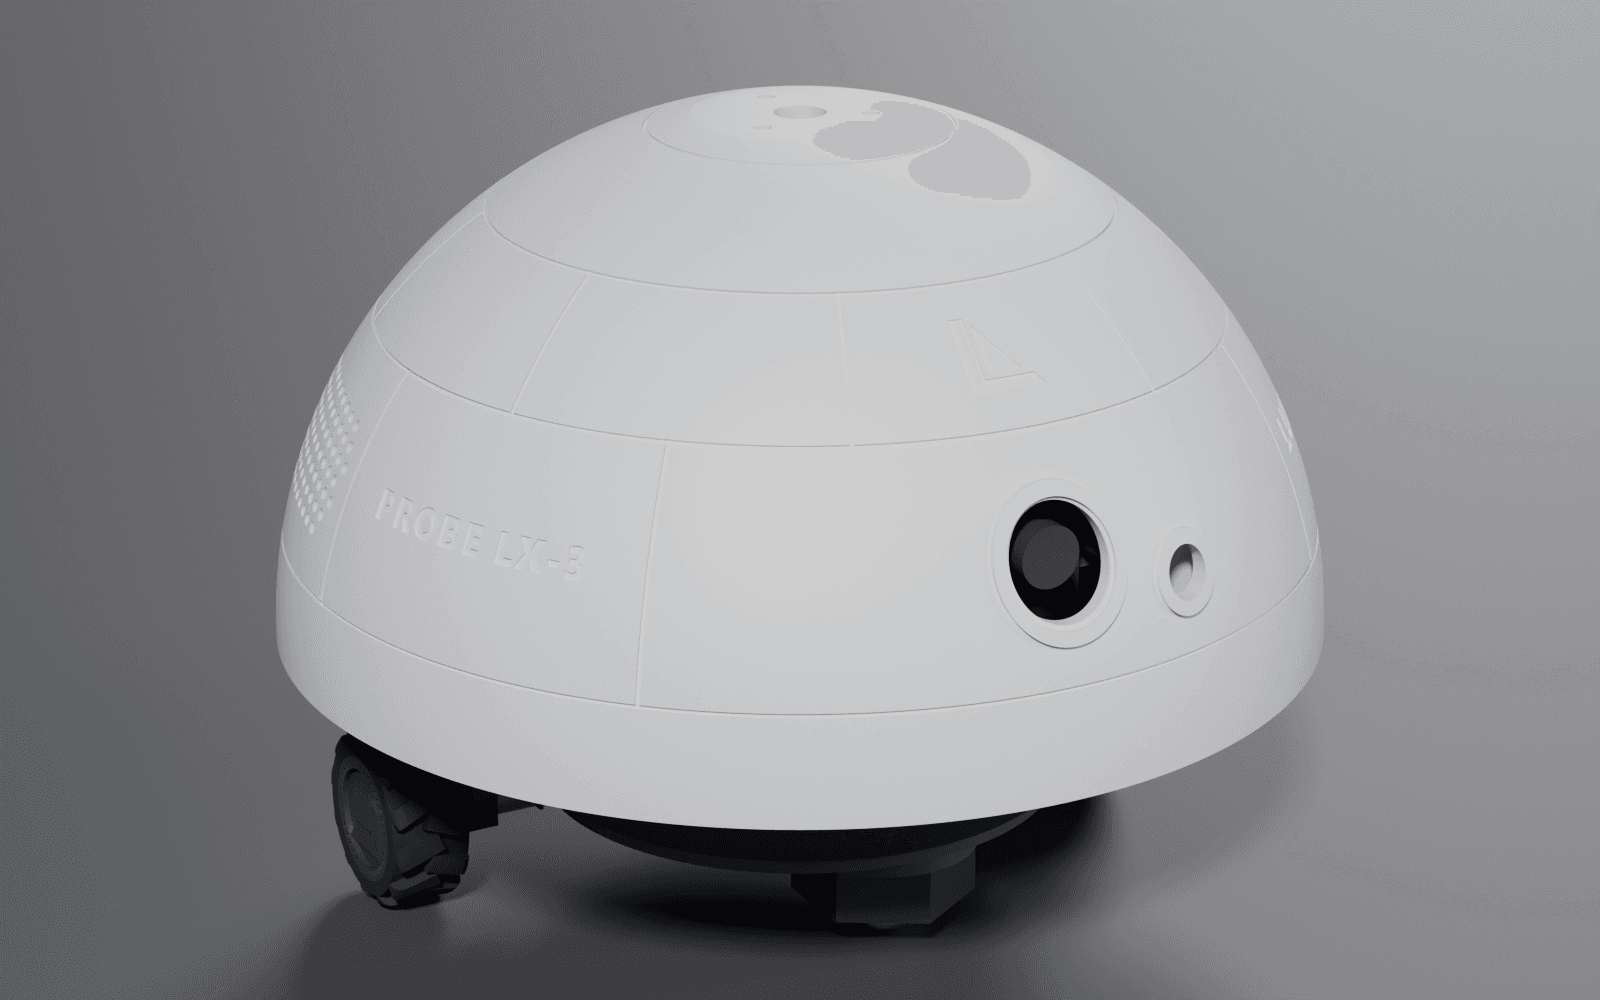
A LeKiwi omni-base robot, driven by a Rubik Pi 3
A self-driving mobile robot that pairs a Qualcomm Rubik Pi 3 brain with LiDAR, a depth camera, and live sensor streaming to Rerun.
Can I build this?Intermediate · AI 4/5 · $500–800
- Difficulty
- Intermediate
- AI-buildability
- 4/5
- Time
- A few weeks
- Cost
- $500–800
Most of the work is software (sensor drivers, navigation, Rerun streaming) on off-the-shelf boards, with a 3D-printed base, some wiring and assembly.
Tools
soldering iron3D printermultimeter
Starter prompt
Based on "A LeKiwi omni-base robot, driven by a Rubik Pi 3" on Afterware: https://afterware.xyz/p/a-lekiwi-omni-base-robot-driven-by-a-rubik-pi-3
Write Python code for a Qualcomm Rubik Pi 3 that reads scans from an RPLIDAR A1M8 and frames from a USB depth camera. Stream the sensor data live to Rerun for visualization. Add a simple obstacle-avoidance loop that sends velocity commands to a mecanum or omni-wheel base over serial.
Estimates based on the original write-up. How AI-buildability is scored. Building with an AI assistant? Connect it to Afterware (free MCP server).
Story
George Igwegbe built a self-driving mobile robot on the LeKiwi omni-base, with the Qualcomm Rubik Pi 3 handling the computing. The robot carries LiDAR and a depth camera and streams live sensor data.
The write-up is short on specifics beyond the hardware stack, but the combination is the point: a single-board computer running perception and navigation on a three-wheel omni platform, with telemetry sent to Rerun for visualization. If you want to build something similar, that pairing of a LiDAR scanner and a live visualizer is the part worth copying.
More like this
More like this
Hardwareby LUMALIEN · GitHub · open hardware Videoby brenpoly · Hackaday